OSTR (Open Source Thunniform Robot)
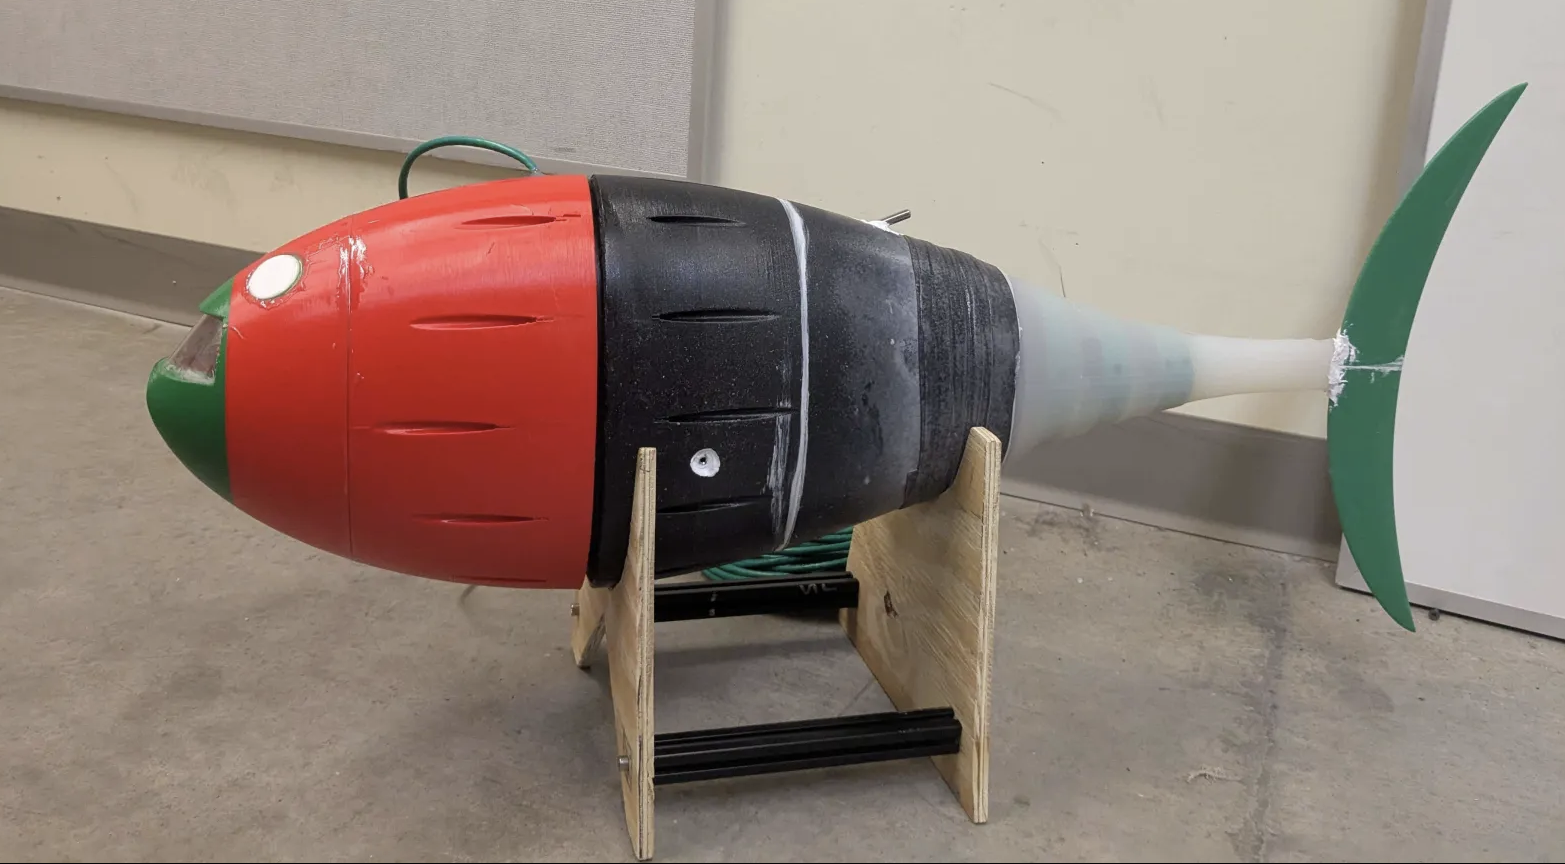
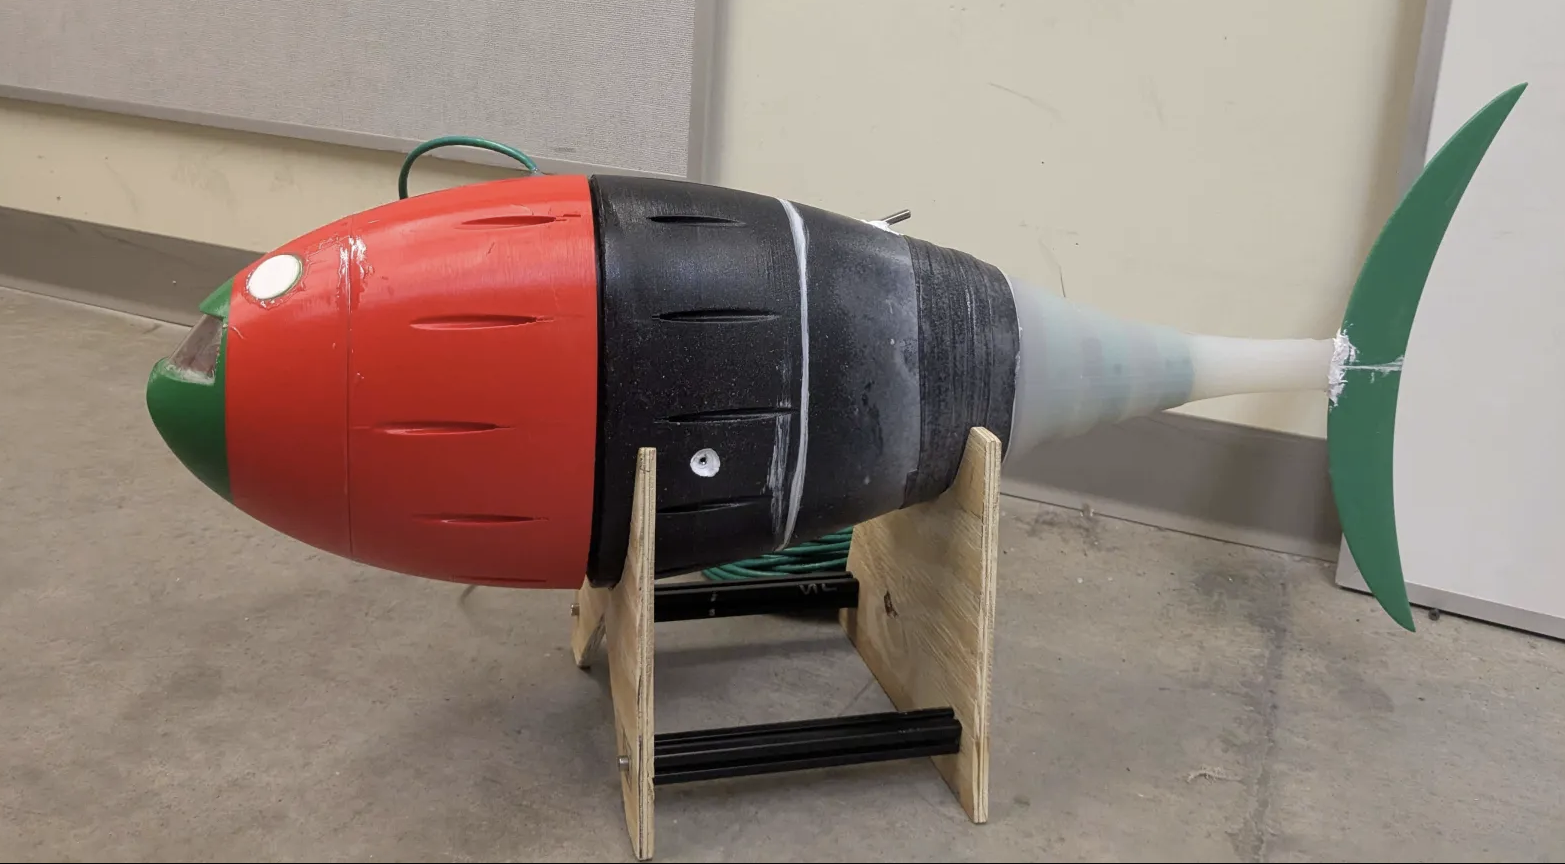
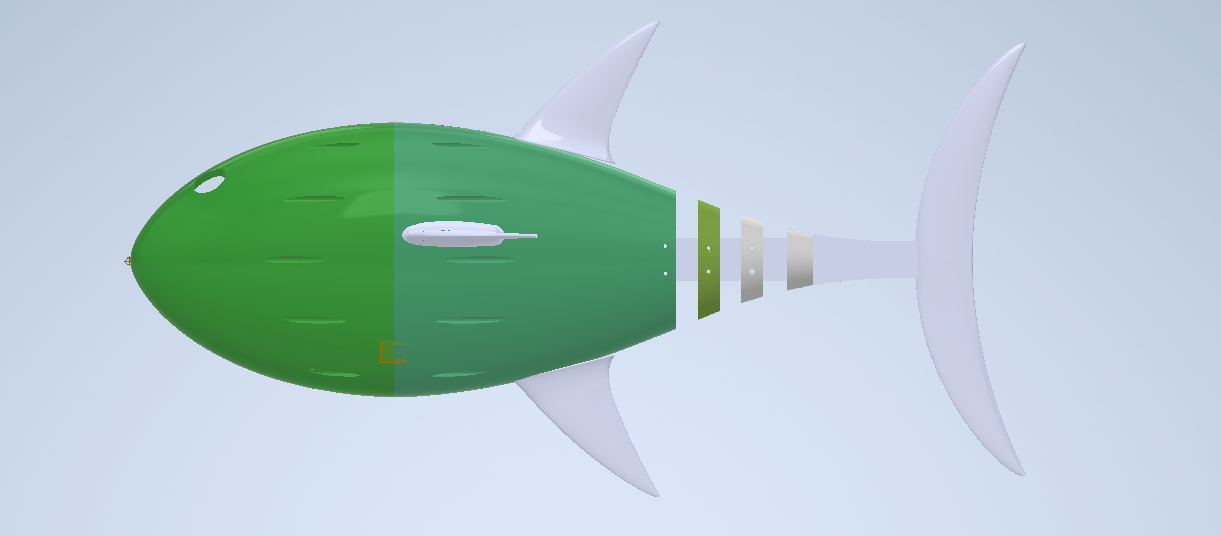
OSTR is a biomimetic underwater robot based on thunniform swimming. The project combines a redesigned body and waterproofing with buoyancy control, yaw steering, wired or wireless operation, sensor interfaces, and an onboard depth-sensing camera. The CAD, Raspberry Pi HAT, and ROS 2 workspace are maintained in the repositories linked under Website.
Project Details
Date: Apr 17, 2025
Team Members: William Forney, Benjamin Keppers, Lucas Haddad, Ike Alafita, Jacob Herrema, Samantha Neveau
Categories: project
Tagged: underwater-robotics, CAD, Raspberry-Pi, HAT, PCB, ROS-2, biomimetics, thunniform, buoyancy-control, wireless-control, sensing
Client: Enterprise-funded
Website: CAD | Raspberry Pi HAT | ROS 2 workspace