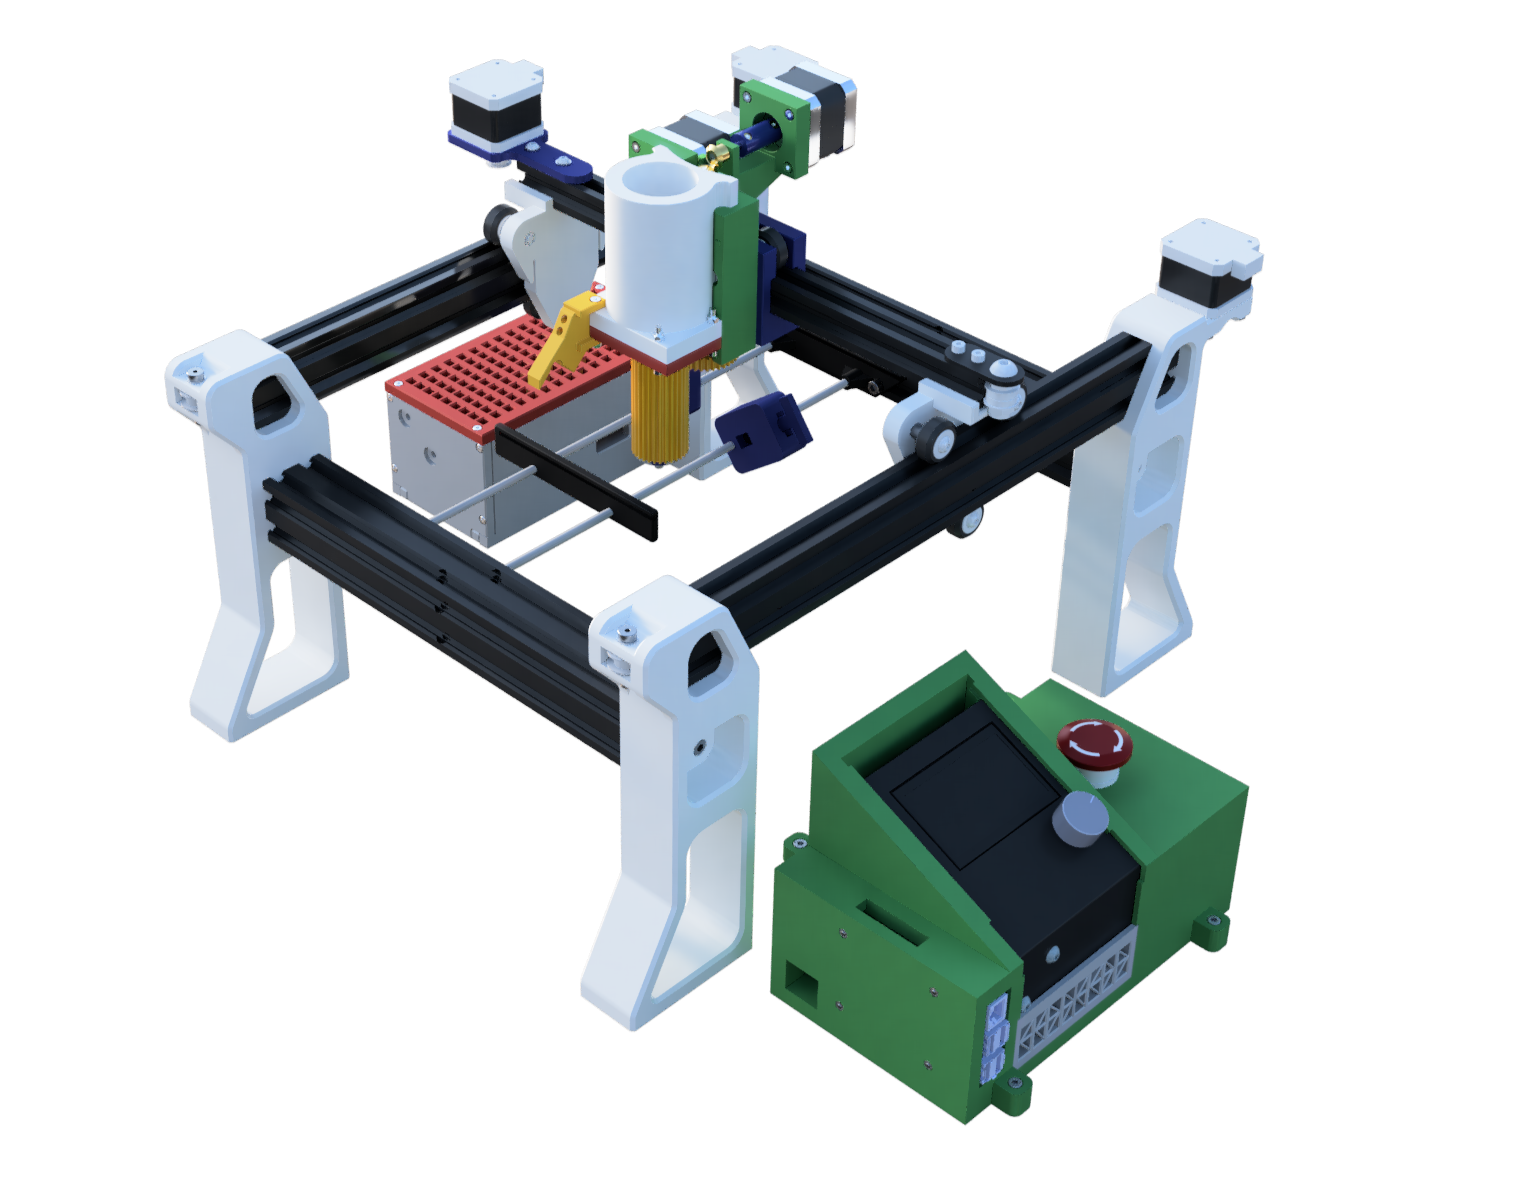
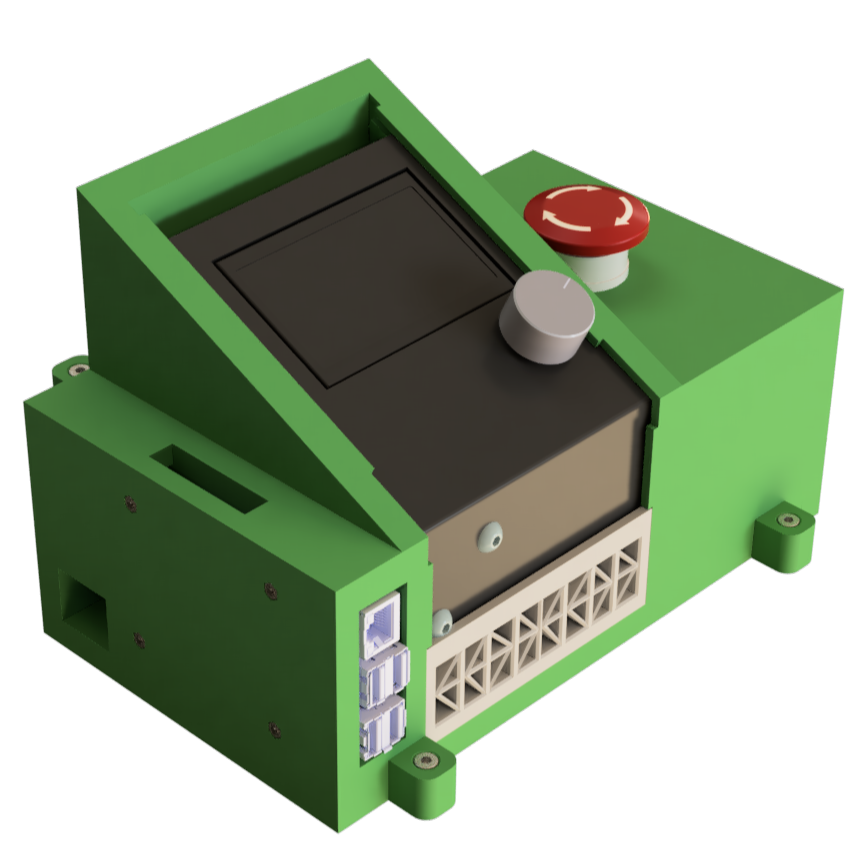
Modular Gantry Toolhead Platform
This project extends the OSHE Pick-and-Place platform with standardized mechanical, electrical, and work-surface interfaces. The first semester specification targets adapting the existing toolhead and prototyping at least one additional interchangeable toolhead.
Project Details
Date: Sep 27, 2026
Team Members: Loyal Schneider, Toby Cufr, Gabriel Fosdick
Categories: project
Tagged: modular-gantry, toolheads, pick-and-place, robotics, workholding
Client: Enterprise-funded